System 01/GPS-denied navigation
Lodestar
Navigation for drones when satellite signals are jammed or faked
Built on the SkySwarm SDK, Lodestar works out where the aircraft is from what its camera sees, and hands that position to the autopilot.
Jamming is now part of every flight.
Over much of today's battlefield, satellite navigation can't be trusted. Drones drift, get pulled off course by fake signals, or never come back. Lodestar lets the aircraft finish the mission using only what it can see.
Overview
At a glance
Own SDK
SkySwarm SDK, navigation software running on board
Passive
Camera and motion sensors only, nothing transmitted
None
Satellite signal needed in flight
On board
Reference maps, loaded before take-off
One cable
Between the module and the autopilot
Day/night
Day cameras as standard, thermal for low light
Rotor/wing
Multirotor and fixed-wing aircraft
Logged
Every flight, recorded on board for review
Offline
Signed updates, no internet connection needed
Preliminary figures, subject to change.
Mission · out and back through jamming
The aircraft flies out, does its job and comes home through jamming and spoofing. When the satellite signal goes, Lodestar is already running, so the autopilot never loses its place.
Lodestar · the map check
The ground below is matched against the map stored on board, and the aircraft learns where it really is. A fake satellite fix drifts away from that answer and is thrown out.
Lodestar · between map checks
Between map checks, the camera follows points on the ground to measure how the aircraft is moving. Points that don't agree, such as moving shadows, vehicles or repeating patterns, are ignored.
Lodestar · fitting · one box, one cable
It mounts under the aircraft with a clear view of the ground and connects to the autopilot the same way a GPS receiver does. Load the maps, set the starting point and fly.
Hardware
One module. Any airframe.
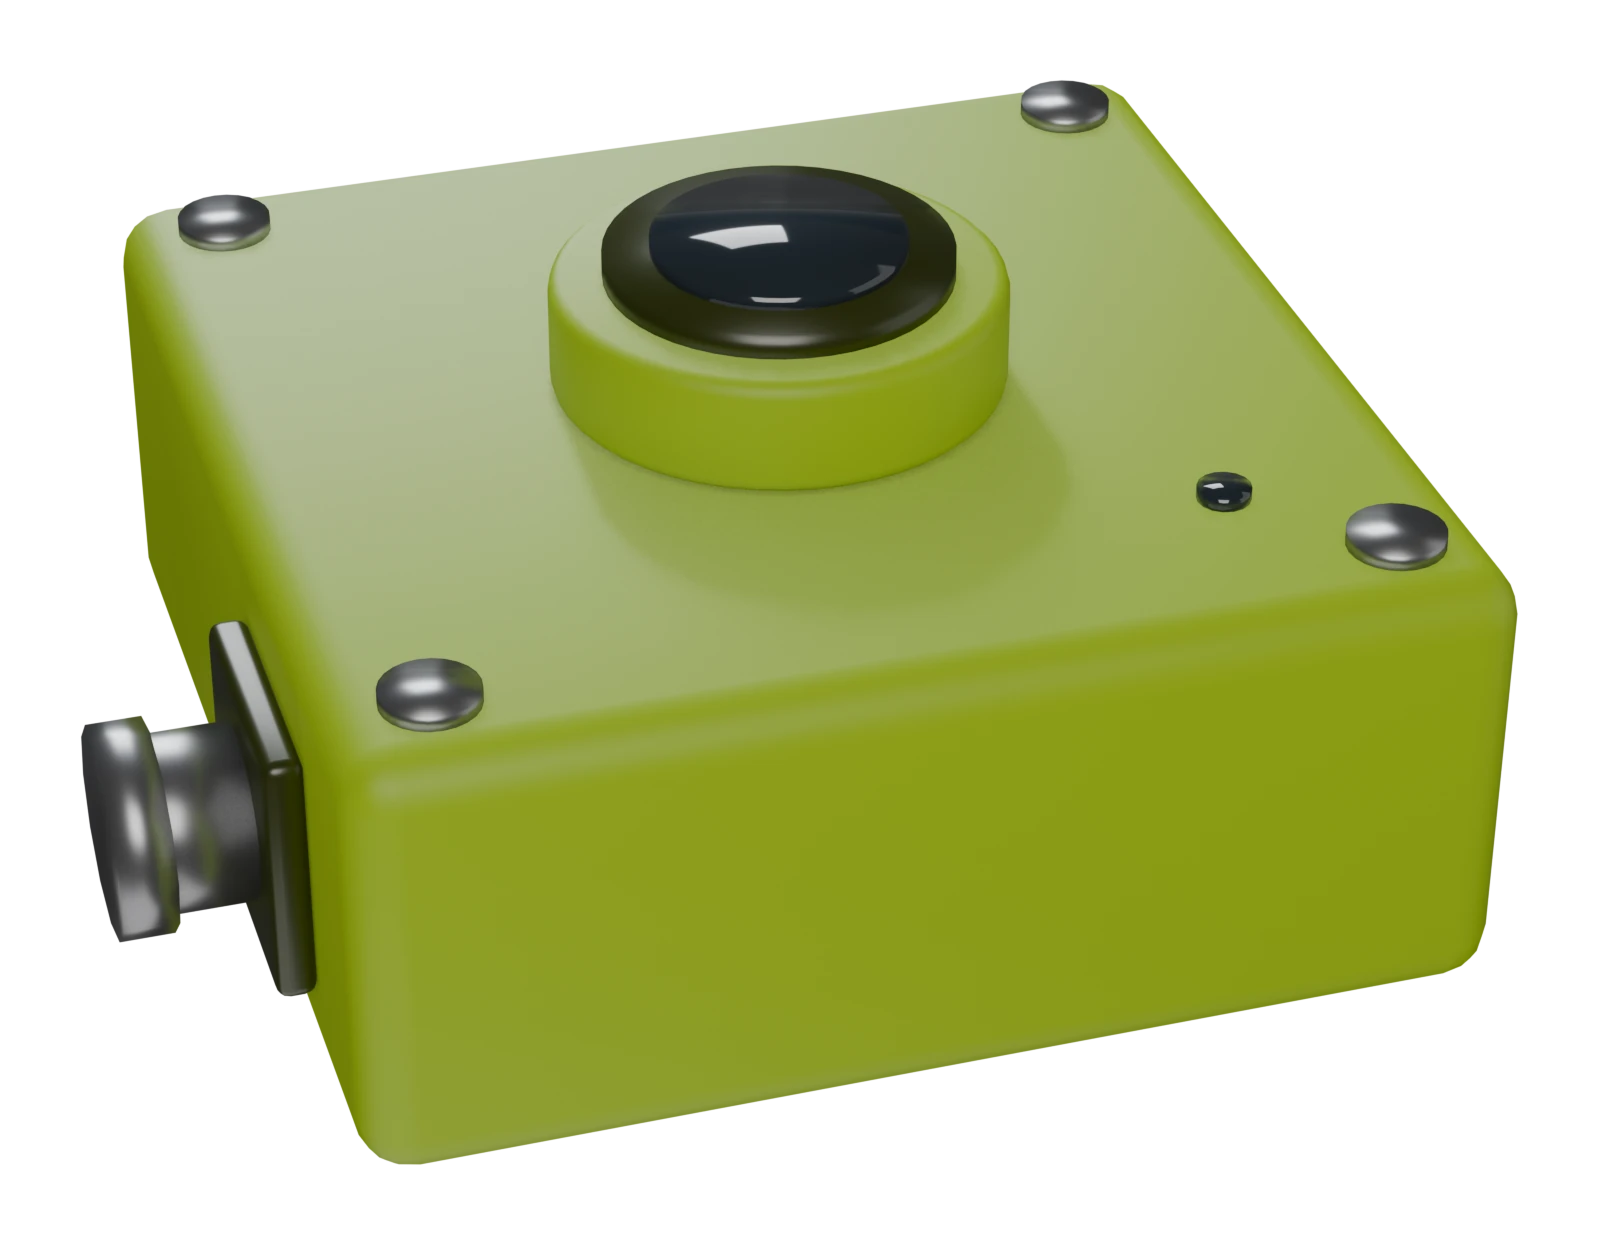
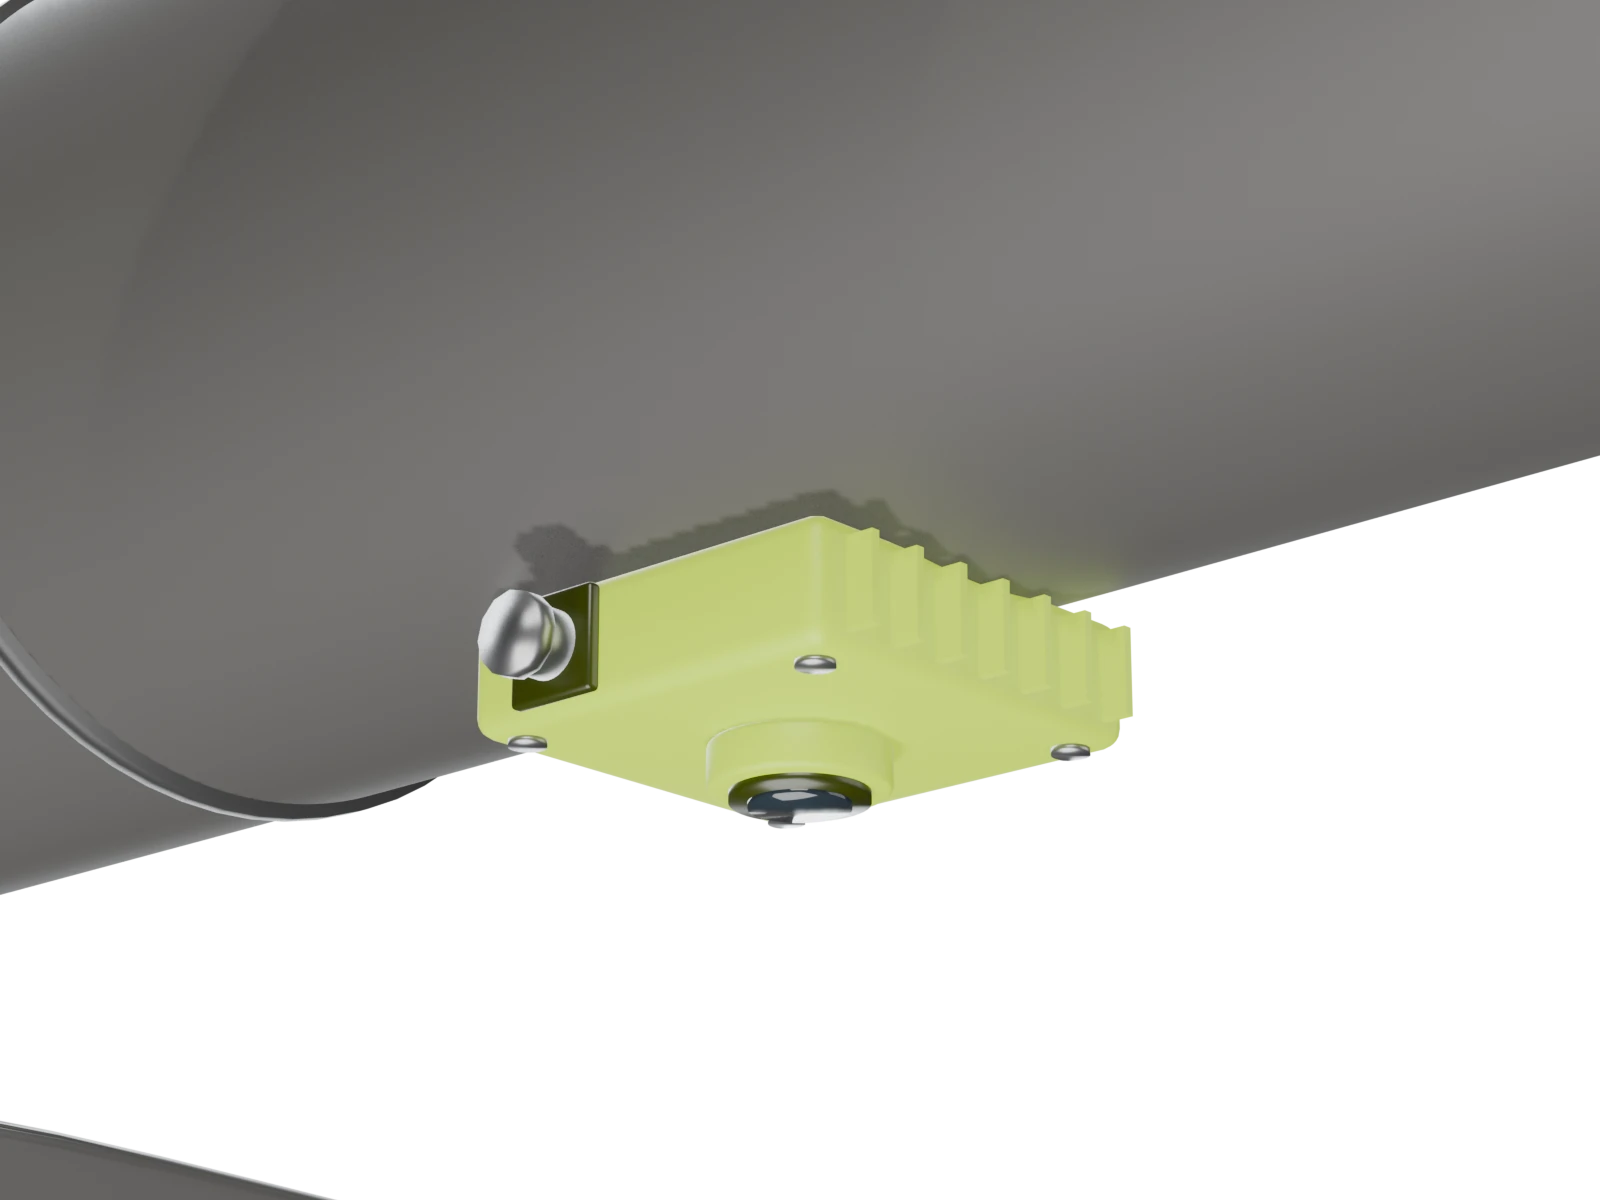
The camera, motion sensors and the computer running the SkySwarm SDK sit together in one sealed housing. It mounts where the aircraft can see the ground and connects to the flight controller with a single cable. Concept renders; the production housing will differ.
[ 01 ]
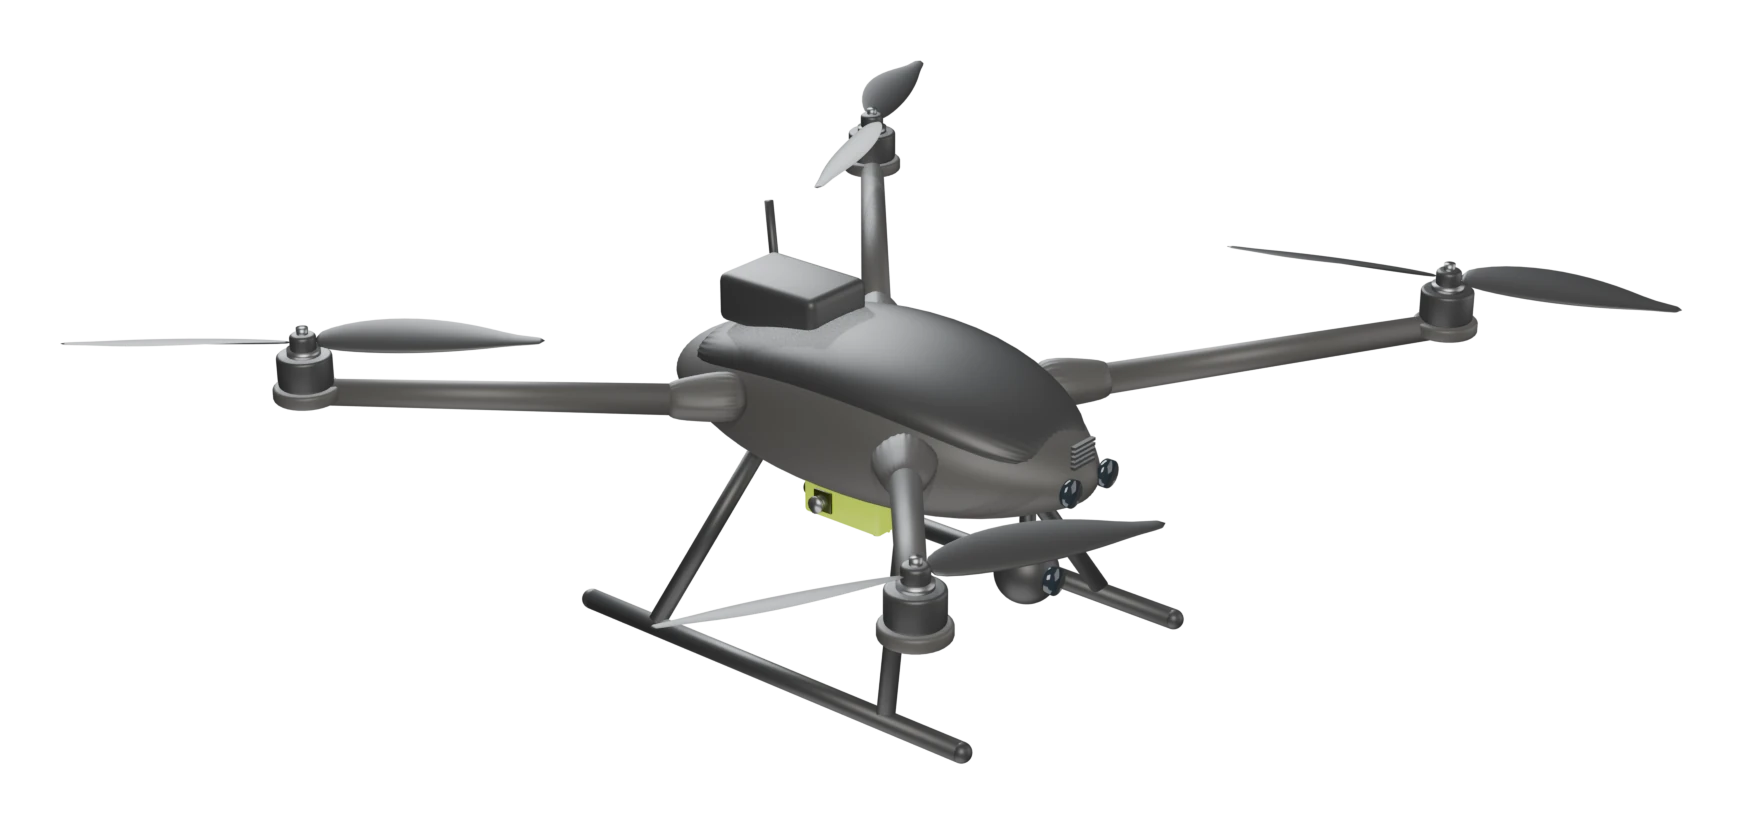
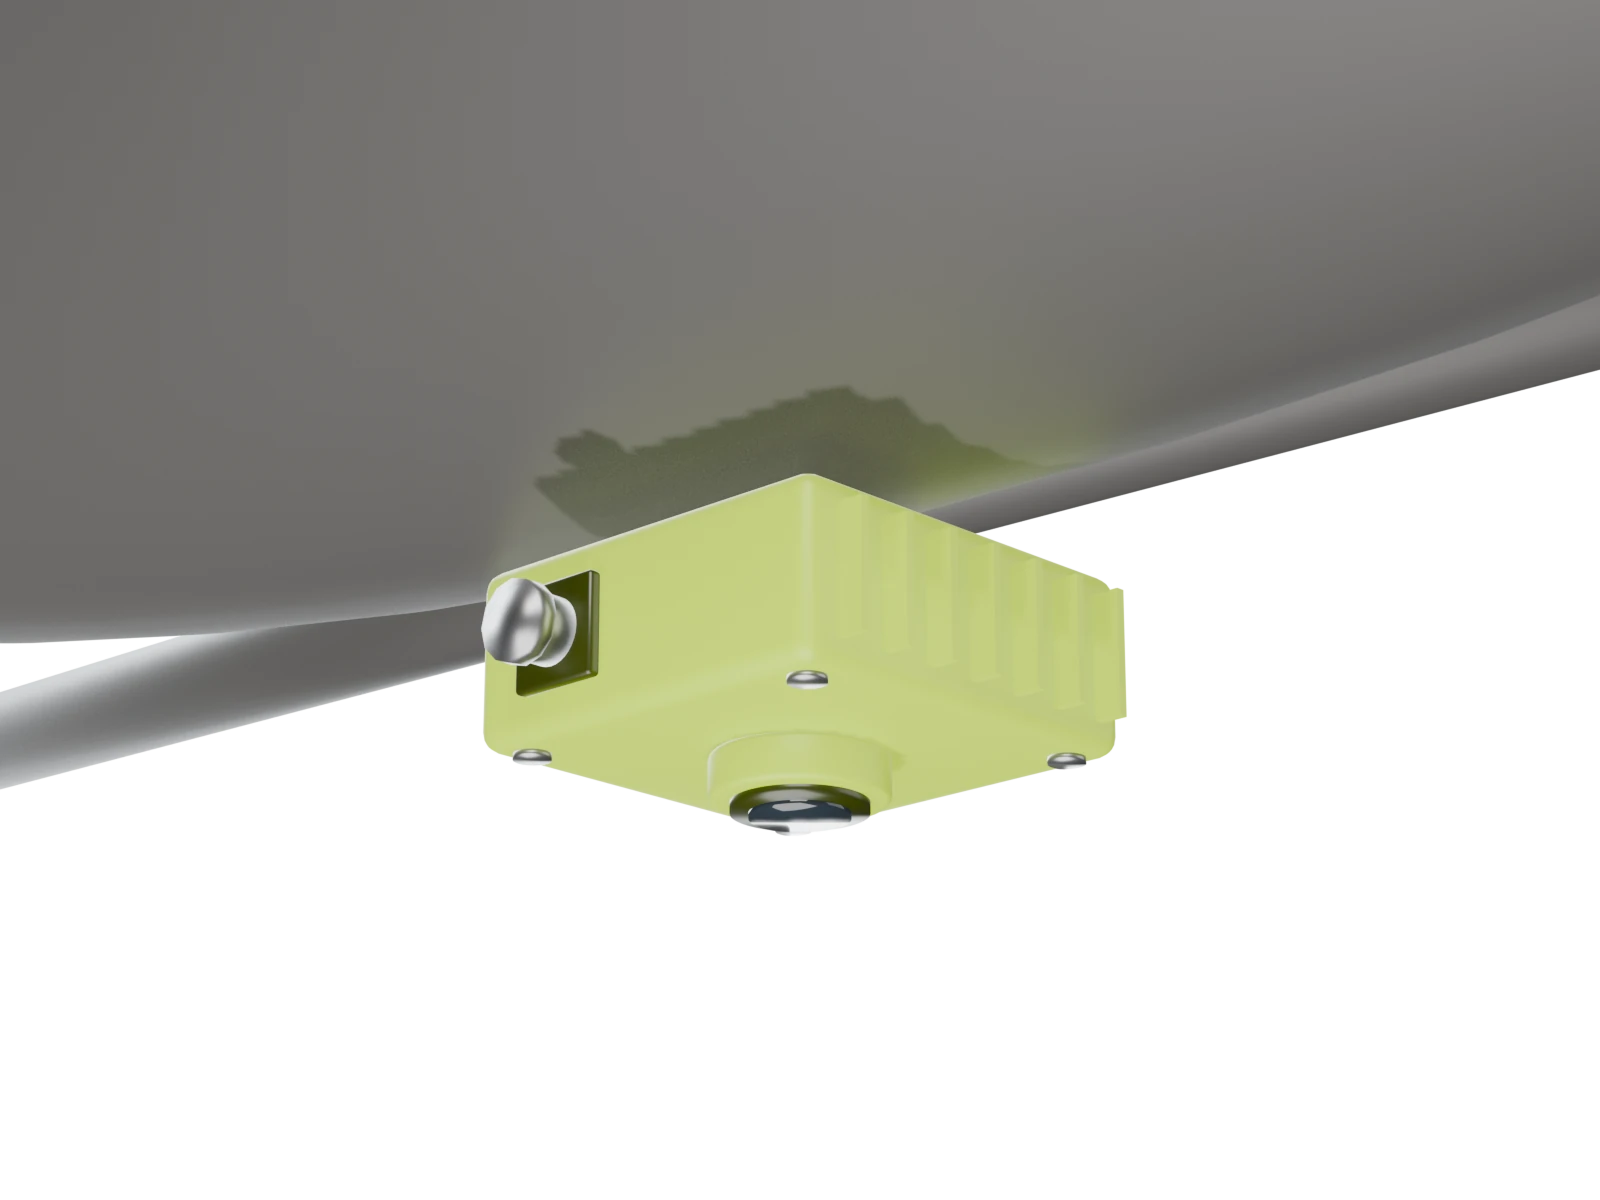
Multirotor
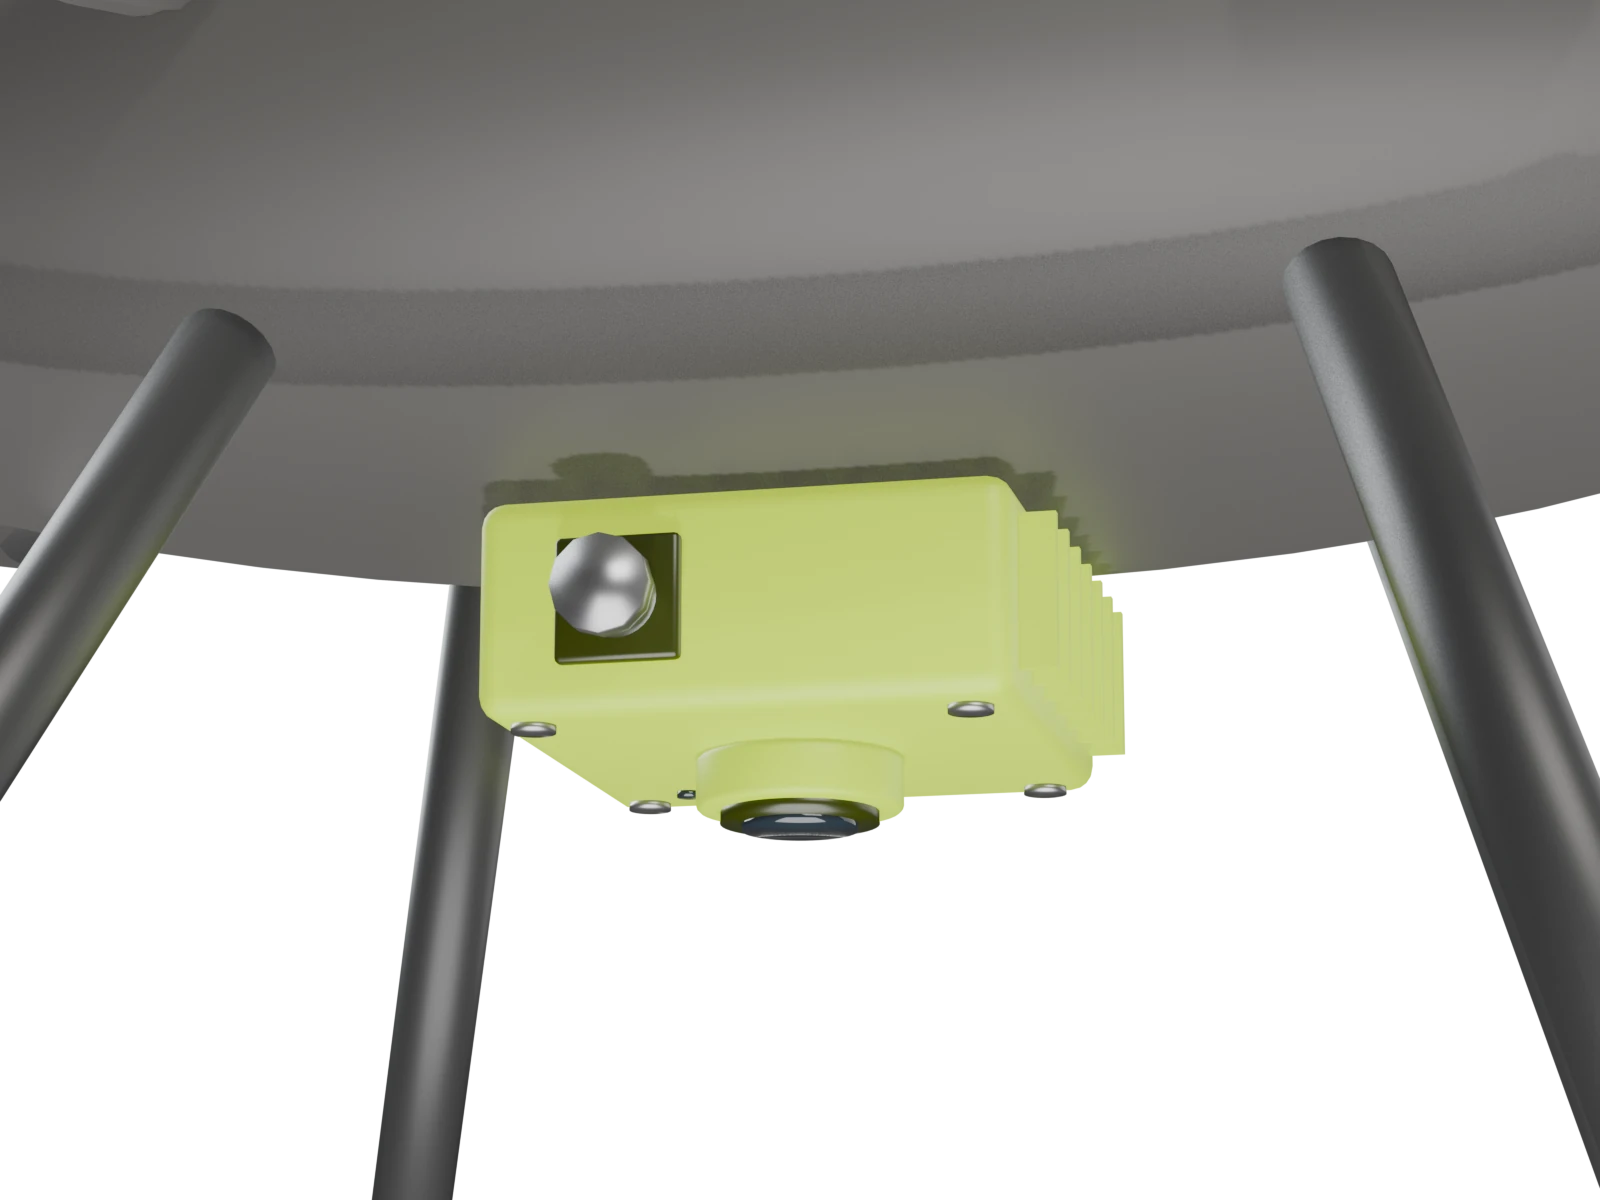
Belly mount · camera facing down
Bolts to the underside of the frame with a clear view of the ground. Takes power from the aircraft and connects to the flight controller with one cable. No change to the airframe.
[ 02 ]
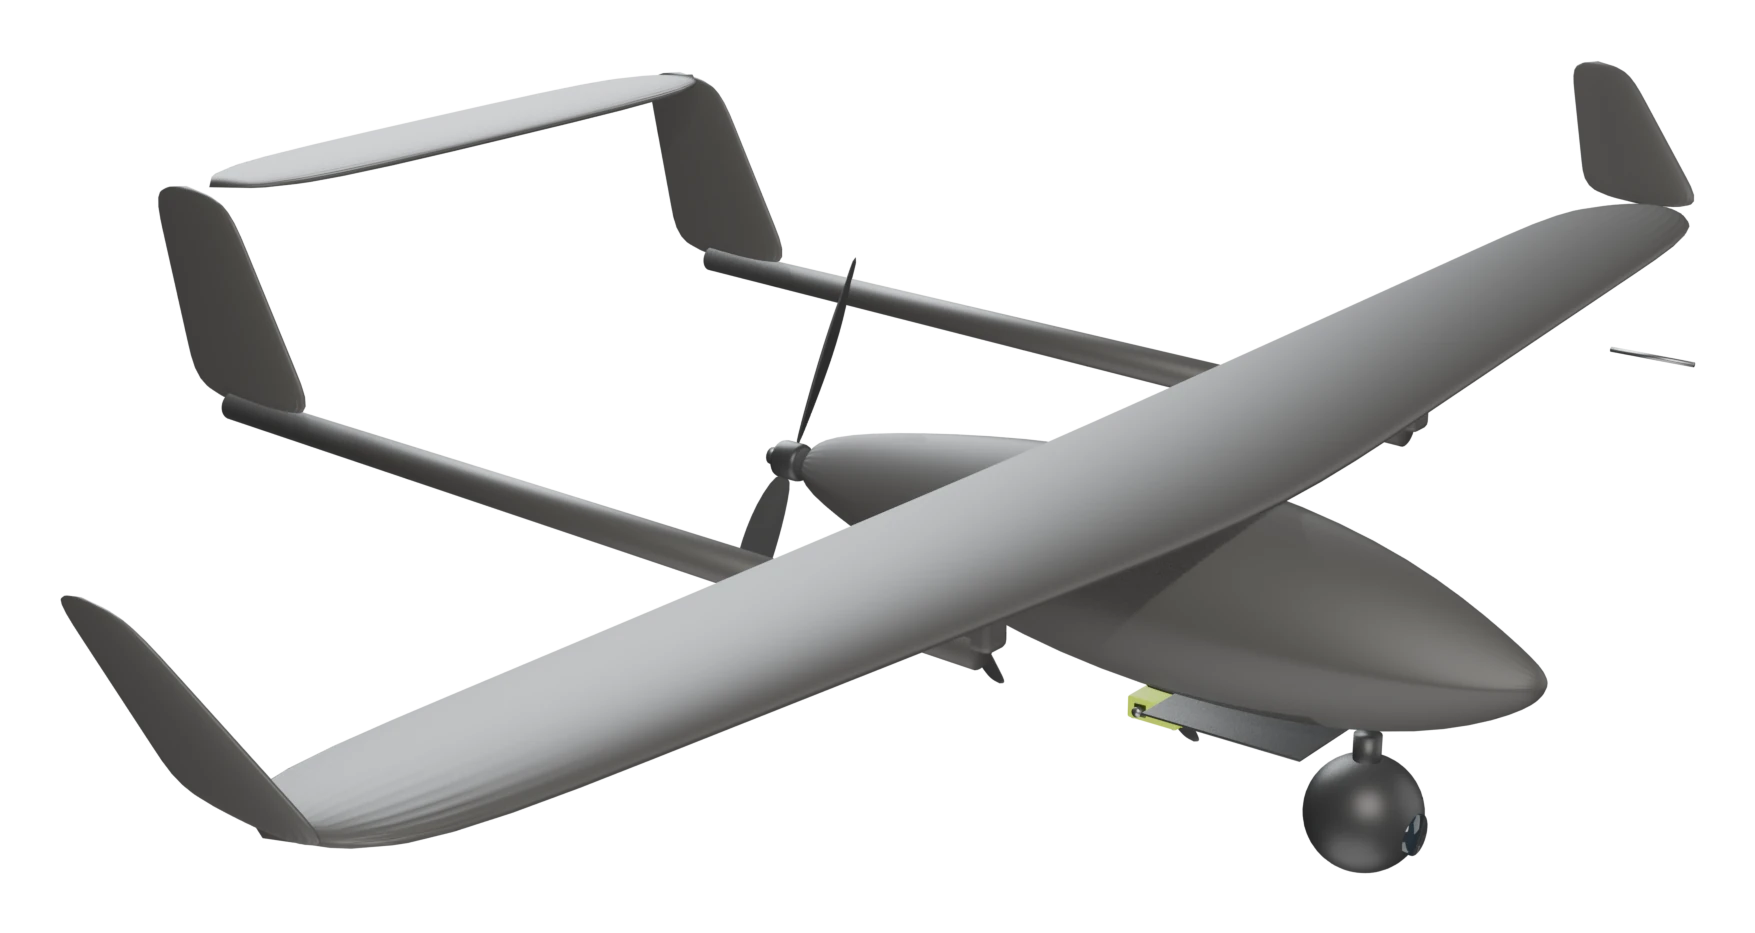
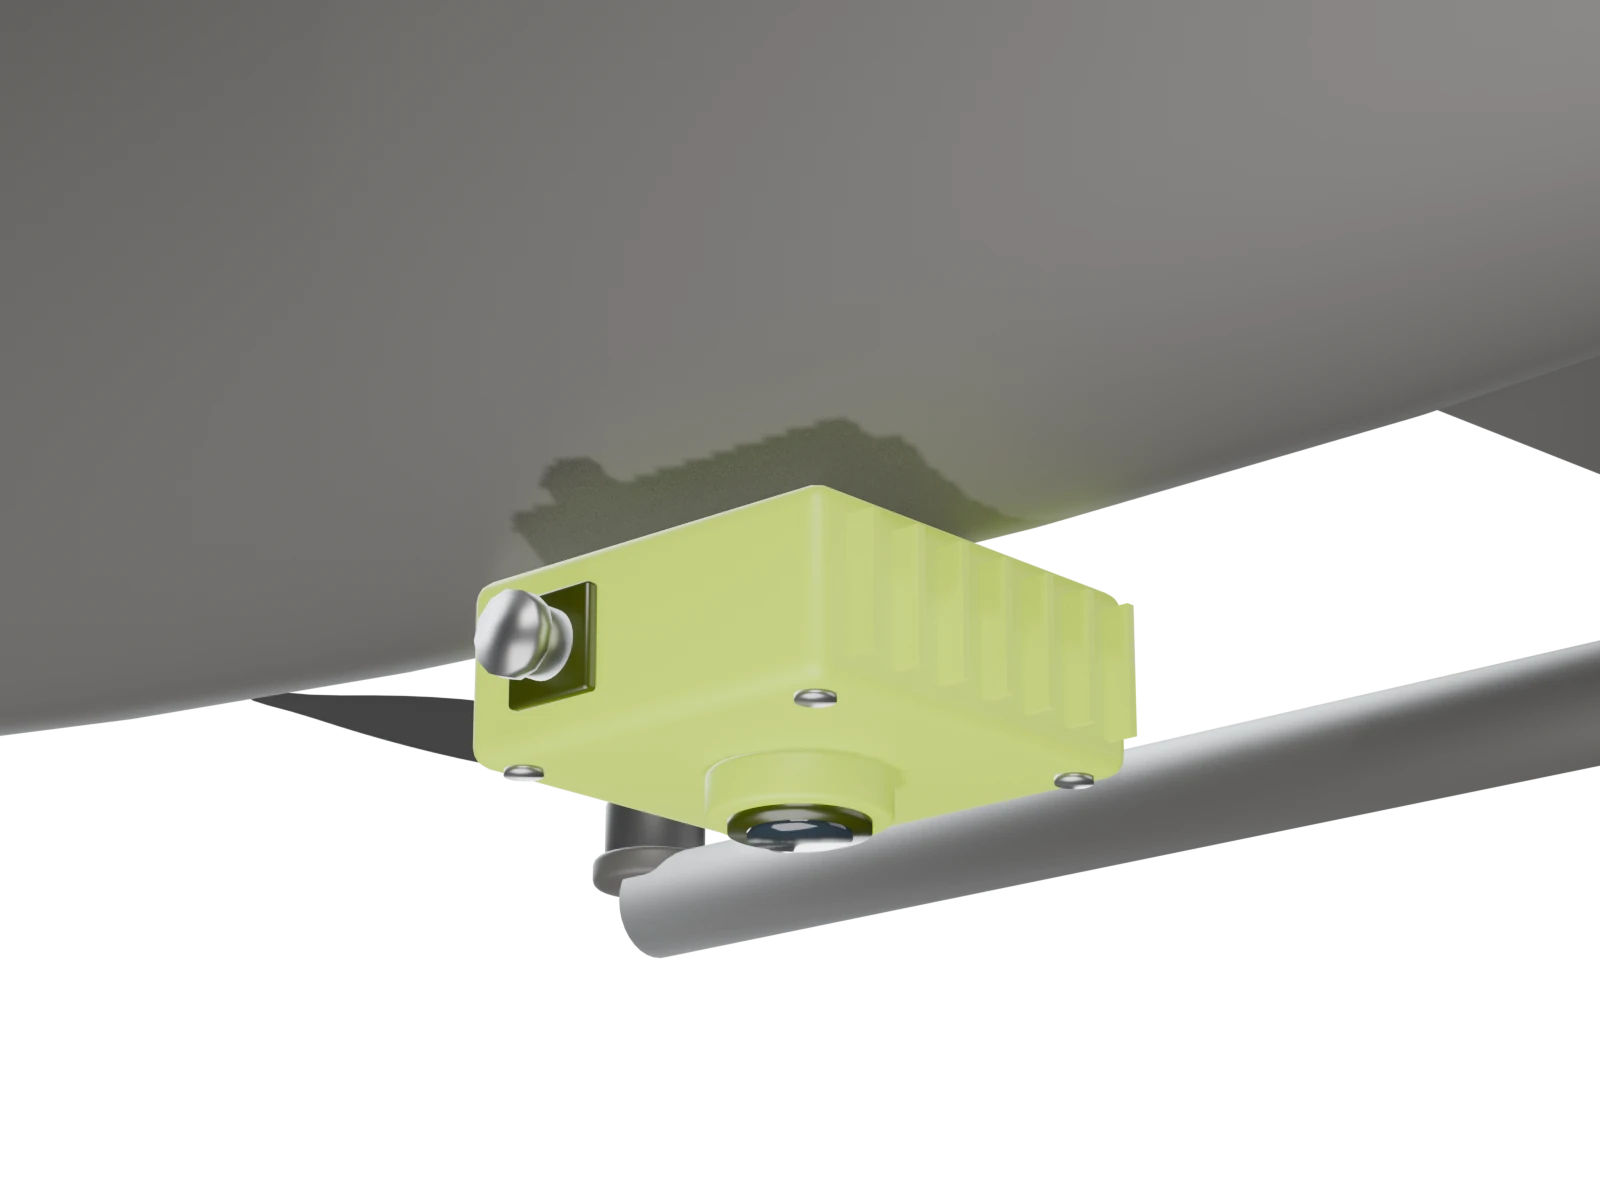
Fixed wing
Under the nose · camera facing down
Sits under the nose where the fuselage is widest, with the camera looking straight down. Suited to long legs, where regular map checks keep the position honest over distance.
[ 03 ]
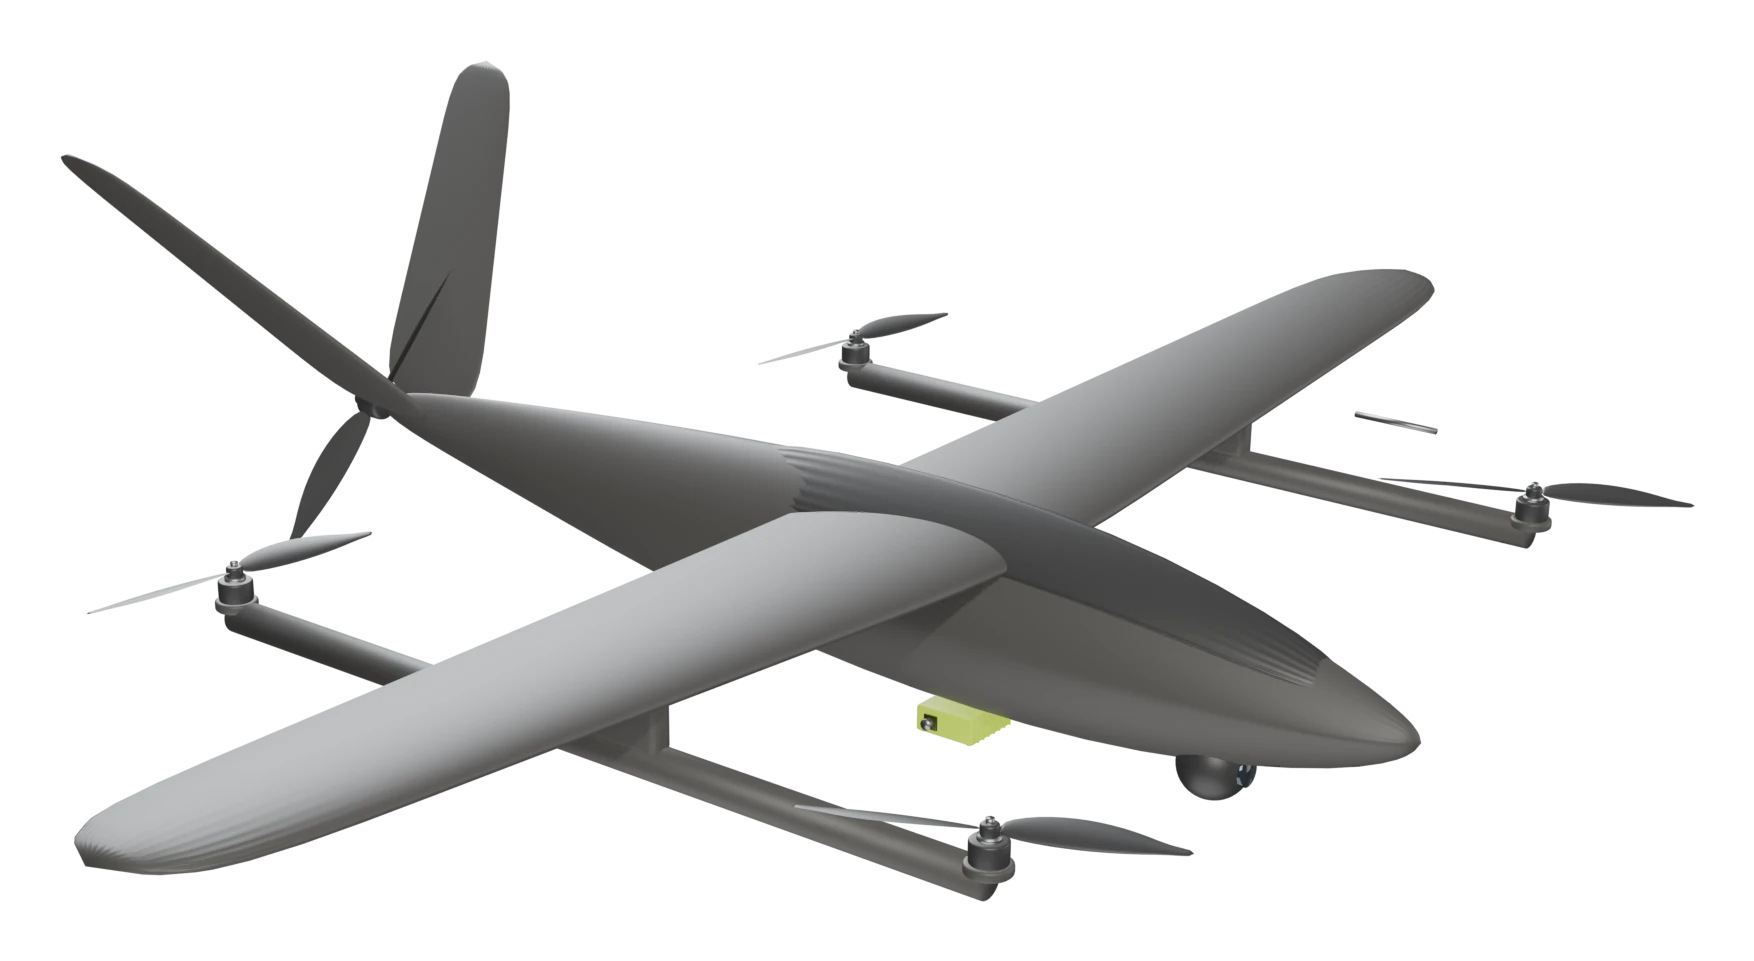
VTOL
Under the fuselage · between the lift booms
Mounts under the fuselage, clear of the lift rotors, with the ground in view from hover through to forward flight. Same unit and same cable as the fixed wing.
[ 04 ]
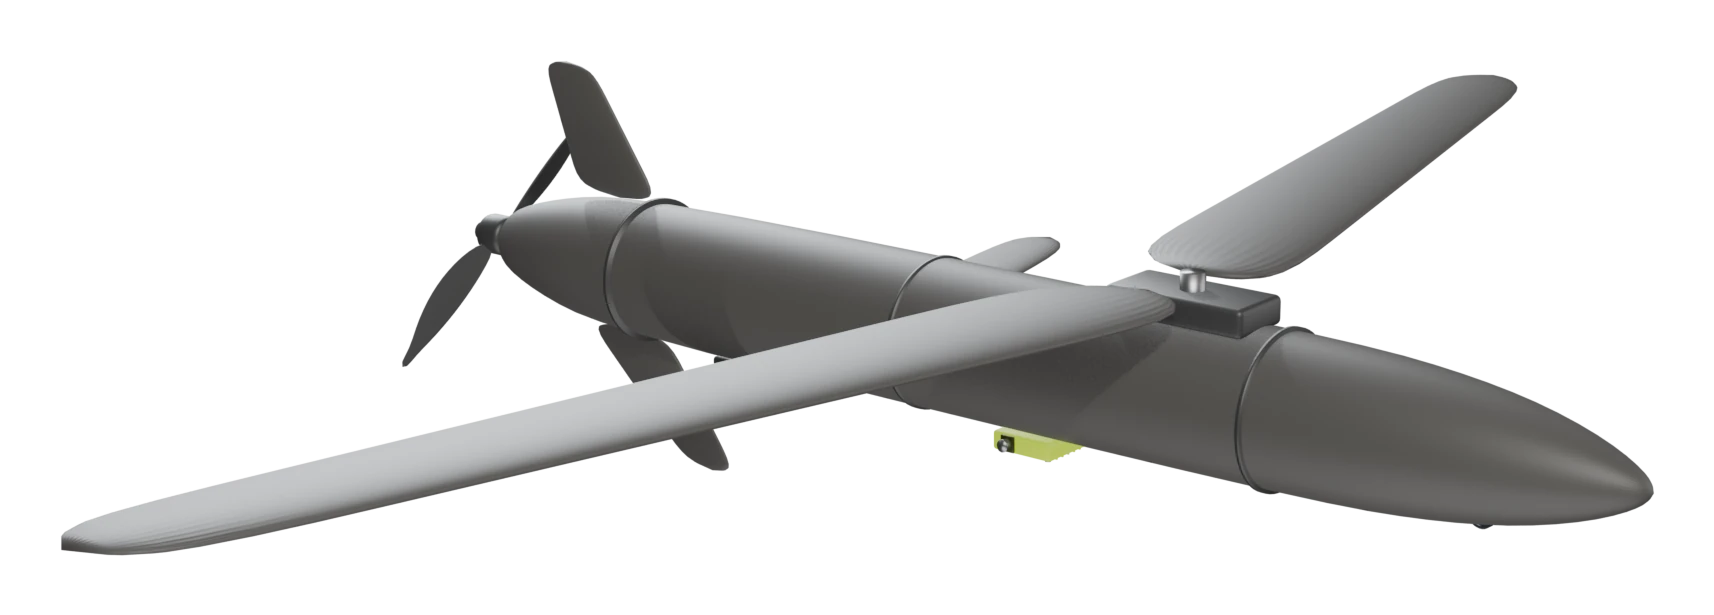
Tube-launched, folding wing
Slim housing · ahead of the wing pivot
A slimmer housing for airframes with no space to spare. It fits inside the launch tube with the wings folded and stays clear of them when they open.
Capabilities
What Lodestar is built to do.
01
Passive
A camera and motion sensors, nothing else. Lodestar never transmits, so there is nothing for the enemy to find or jam.
02
Knows where it is
Matching the ground against the map gives a true position, not just an estimate of distance travelled. Errors don't pile up on long legs.
03
Ignores fake signals
If a satellite receiver is fitted, its position is checked against Lodestar's. When the two disagree, the satellite fix is dropped.
04
Only trusts good fixes
Each map match is scored before it is used. Weak matches are discarded, and the autopilot is told how far to trust the rest.
05
Drop-in for the autopilot
The autopilot sees one more position source. Missions are planned the same way, and the aircraft flies them the same way.
06
Checks itself
Camera, sensors and timing are watched throughout the flight. Problems show up on the ground station, and every flight is recorded for review.
Integrates with
Standard interfaces first. Vendor-specific work is scoped per platform during the demonstration.
See Lodestar on your platform.
Integration is scoped in days, not quarters. Tell us the airframe, the autopilot and the environment.
Request a demonstration